Servos
Servos are the particular robot units associated with your business. A model describes a robot type; a servo record identifies the unit you intend to connect, inspect or operate. Creating that record does not establish a working device connection.
The reviewed test business had no linked robots. We inspected a filled-in setup draft and the implementation behind the device features. No robot was enrolled, moved, updated or accessed through a shell. Live-device features below are source-confirmed, with their untested limits stated explicitly.
Servo Management
Open Servos and distinguish Your Servos from Servo Models. Use the model catalog to identify a type, not to infer that a physical unit is connected. Model availability can depend on beta access.
- Check the selected business.
- Choose Add Servo, then select the model matching the physical unit.
- Give it a name that identifies its role and unit, such as Workshop inspection Go2.
- Review Continue deliberately: this creates a pending unit record and opens installation, rather than merely advancing an unsaved form.
- Complete installation on the intended robot, then confirm the resulting device identity and reported connection state.
- Open the unit to inspect its details and available controls. Use Show Archived when looking for an archived unit.
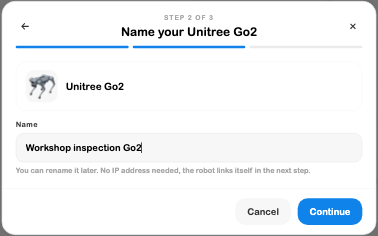
Pending setup records can contain initial status values. A saved map position, battery value or signal indicator is not proof that the robot measured it. Confirm enrollment, last-seen time and real telemetry before treating any value as current.
ServoConnect Installation
The installation step provides an expiring command and QR for linking the actual robot to the selected unit. Run the provided command only on that intended robot, then wait for the panel to report connection and verify the device identity.
If a code expires, use New code rather than relying on an old screenshot or copied line. Finish later can leave setup pending; a pending record is not an installed agent. Existing units can offer installation or reinstallation through Manage → Device.
The installation command, claim code and QR contain linking material. Keep them out of public documentation and shared screenshots. This review stopped before generating them, so it does not verify installer download, enrollment, restart persistence or robot connectivity.
Live Servo Location
The unit detail can display Current Location or an Approximate area, depending on the data reported. Review the label and the source's recency before treating a marker as the robot's current position.
Supported device location inputs include GPS-capable adapters; an indoor camera or an installed agent alone does not guarantee a GPS fix. The Maps live layer is another way to view shared positions, and distinguishes fresh from last-known records.
No live location was received in this review. No map marker was fabricated from setup defaults, and no device was asked to share its location. A stale or approximate position should not be used as proof of successful movement or arrival.
SSH Terminal
The unit's Manage workspace distinguishes remote shell access from direct local-network SSH. Opening a terminal is separate from steering or updating the robot.
For an enrolled device, the remote terminal uses your SRVZ sign-in and server-checked access. The account owner can choose whether authorized team members may open the shell; legacy setups have narrower owner-only handling. The Device → Terminal access controls and Login & permissions link help review that scope.
Local-network SSH is a separate connection mode requiring the correct host and SSH authentication. A visible IP address or an online badge does not prove a shell session works. Do not put passwords, keys or terminal output containing credentials into public support images.
The terminal UI, authorization path and mode distinction were inspected in source. No robot terminal was opened and no command was run during this documentation review. Consult the reported connection status if a session fails rather than assuming a blank terminal is connected.
Lidar Scans
Supported robot sessions expose Live LiDAR through the remote-operation side panel. A working view needs a compatible sensor, active data stream and usable session; it is not created by adding a servo model.
Inspect point counts and incoming updates before interpreting the view. Quality controls can trade displayed detail for rendering performance. A previously accumulated point cloud can remain visible without proving that new measurements are arriving.
LiDAR point clouds, a GPS location and the separate Room Scanning workflow describe different things. Do not describe every depth or camera view as LiDAR, or treat an accumulated scan as a verified navigation map.
The viewer and stream controls are source-confirmed. No sensor stream, scan export, mapping accuracy or robot navigation was tested, and no empty point-cloud screenshot is presented as a scan result.
Audio Streaming
A robot session can distinguish audio sent to the robot from monitoring the robot's microphone. The Audio module offers sources such as a file, microphone or generated speech; availability depends on the active connection and service setup.
Review the intended source and output before starting playback or microphone input. Browser microphone permission and autoplay behavior can affect whether sound actually flows. A robot microphone monitor being enabled does not prove that incoming audio frames are arriving.
The implementation handles audio-capable streaming separately from hardware video modes that do not carry audio. A clear video picture therefore does not establish working talk-back or listening. Starting an audio function can require reconnecting with a suitable stream mode.
No microphone permission, speech generation, playback or robot audio stream was started in this review. File selection, generated-speech setup and successful physical audio output remain unverified.
Servo Accessories
A dedicated servo-accessory inventory or configuration workflow was not found in the reviewed app. The model, agent adapter, sensor support and actual installed hardware remain the relevant sources of capability.
Do not assume that a microphone, GPS adapter, gripper or other accessory is connected because its related tool appears in navigation. Confirm the physical equipment and its supported integration before describing it as available. Rental accessory management is a separate business workflow, not proof of robot accessory pairing.
Robot Software Updates
Manage → Device can show the installed agent version, available release, update progress and diagnostic tools. Agent software updates are separate from robot policy checkpoint deployment.
Review the installed and target versions and the chosen Stable or Beta channel. An available-update label does not establish that the target is installed. After an authorized update, inspect the returned state, restart and reported version.
Where allowed, the device controls include Install updates automatically, manual update, rollback, Run checks and View logs. Automatic checks are implemented on a recurring schedule; a configured switch does not prove that an offline robot applied an update. Read the actual results and failure reason rather than treating an accepted request as completion.
These controls were inspected in source only. No update, restart, diagnostic command, rollback or access-setting change was sent to any robot. Logs were not collected or published.
Troubleshooting
| Symptom | What to check |
|---|---|
| Unit remains pending | Installation and enrollment have not been confirmed; naming a unit is only setup. |
| A location or battery value seems wrong | Verify fresh device telemetry rather than initial record values. |
| Terminal access is denied | Check owner/team access and whether the device uses the current enrollment setup. |
| Video works but audio does not | Check the audio-capable stream mode, selected source and browser permissions. |
| LiDAR view has no new points | Check the sensor, active stream and session; an old cloud is not new data. |
| Update was requested but version is unchanged | Inspect device connectivity and reported update phase/result. |
Continue with Remote robot operation, Policies and Team devices.