Policies
A robot policy is behavior code or a checkpoint prepared for a particular robot interface. Keep its model, files and version identity together: a named policy, an initialized simulator and an installed robot version are different results.
This review used a Go2 standing rehearsal setup draft and the actual browser simulation. It did not create a repository, train a policy, publish a checkpoint or send a deployment command to a robot.
Policy Trainer
Open Policies → Create Policy to choose a name, code template and simulator scene. Make the intended robot explicit in the name so experiments are easy to distinguish.
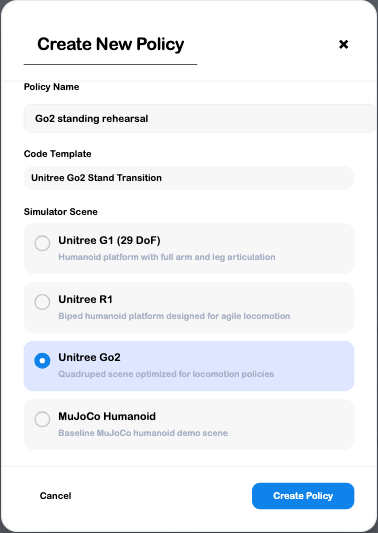
- Choose a code template that matches the experiment. The reviewed choices include walking, Go2 trot and stand-transition examples, plus a zero-action baseline.
- Choose the matching scene. The setup offers G1, R1, Go2 and the baseline MuJoCo humanoid.
- Review the creation action before completing it. It attempts to create and initialize a GitHub repository, then save a policy resource and open its trainer. Repository access must work; entering a name is not a completed save.
- For an existing policy, open its workspace and review its actual files. The chooser distinguishes the original trainer from the newer beta trainer; their execution requirements differ.
- Inspect the model and controls before running the intended code. A scene loading correctly does not show that the policy file is compatible or executing.
Inspect the simulator deliberately
The browser trainer loaded a real Go2 model. Its Get State, Reset and Reset Camera controls help inspect and repeat a simulation setup. The reviewed Get State action returned a simulation-state message, and Reset returned the scene to its starting state.
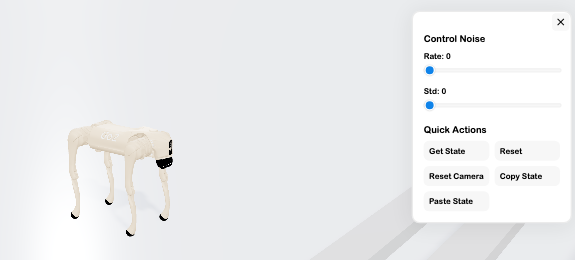
Use Run Policy only after reviewing the intended file and model. Treat errors and terminal output as part of the result. Zero reward, loss or iteration counters do not establish training progress, and a Saved indicator without a loaded project does not prove a repository commit.
The original trainer executes policy code through its browser simulation environment. The beta trainer has separate execution-service requirements. A working original scene does not prove the beta execution service is available. Neither trainer was used to run a policy during this review.
Cloud Policy Training
A cloud policy-training submission workflow was not found in the reviewed app. Training Runs currently states that training-run management is coming soon.
Do not interpret the trainer's iteration, reward or loss panels as proof that a cloud job is running. Likewise, cloud business agents and remote code execution are different capabilities from submitting and managing robot training jobs.
Before planning a training run, confirm the actual supported execution environment, resource configuration, progress reporting and resulting checkpoint. No cloud training job, compute allocation, cost or checkpoint output was verified here. The guide does not provide a submission procedure for a placeholder page.
Policy Deployment
A deployable checkpoint needs a published version with the expected artifacts and interface, plus compatibility with the target robot. A policy listed in the workspace is not automatically such a checkpoint.
Before requesting deployment, review:
| Item | What it establishes |
|---|---|
| Version and channel | The identified release, rather than an unnamed working file. |
| Robot model and interface | Whether the checkpoint is intended for this target. |
| Release report | Available gate results, metrics and known issues. Missing evidence is not a pass. |
| Artifact and signature information | The packaged release's verification information; a version name alone is insufficient. |
| Target selection and access | Which robots the request will affect and whether you are authorized to change them. |
Where a published compatible version is available, the deployment dialog offers eligible robot selection and returns per-robot results. Interpret an accepted request as requested, not installed. The robot reports download, verification, self-test and activation phases separately.
The trainer's publication/deployment menu was opened in this review and showed no online servos. No checkpoint was published or installed. Robot-side file verification, idle handling, activation and a first physical run were not tested. Use Servos to inspect the actual target and reported state before considering operation.
Robot Fleet Rollouts
The deployment implementation supports staged rollouts across selected compatible robots. A percentage determines the first group; rollout controls can pause, resume and advance the remaining stages. This helps distinguish a limited introduction from a fleet-wide assignment.
Review the selected version and robot list before starting. Track the assigned count, percentage, failures and status together. Assigned does not establish successful installation or behavior. The current rollout interface advances in percentage steps; do not treat that control as a per-robot physical readiness check.
The implementation pauses a rollout when it records a failure. Investigate the failed phase and affected robot before resuming rather than increasing the percentage to make progress appear complete.
These controls and server rules were inspected in source. No populated rollout, pause/resume action, automatic failure handling or fleet installation was exercised or photographed in this review. There is no synthetic fleet screenshot standing in for connected robots.
Robot Deployment History
A robot's policy-management view can show its active version, pending request, last result and install/rollback history. Those fields answer different questions:
- Pending request identifies a change the robot still needs to pick up.
- Current phase explains whether it is waiting, downloading, verifying, testing or activating.
- Last result records the outcome and any reason reported for that attempt.
- History helps trace earlier version changes and failures.
Use the exact version and phase when investigating a mismatch. A marketplace release date, a server-accepted request and an on-robot activation time are not interchangeable.
Rollback is a separate change request to a prior version, not an automatic guarantee that the previous behavior is already active. Confirm the robot's reported result after the request. Update-channel and automatic-update settings also affect later behavior; the implementation restricts those settings to the account owner.
History and rollback behavior are source-confirmed only in this review. No device history was fabricated, no update settings were changed and no rollback command was sent.
Troubleshooting
| Symptom | What to review |
|---|---|
| Policy creation fails | Repository authorization and file initialization, not only the policy name. No successful creation was tested here. |
| Simulator loads but nothing runs | Confirm the intended code file, model and execution environment; rendering is not execution. |
| Metrics remain at zero | Verify that a real run produced metric updates. The default panel is not training evidence. |
| Training Runs has no controls | It is currently a placeholder, not a verified cloud-job manager. |
| Deployment has no eligible targets | Check published artifacts, interface, model compatibility, permissions and available robots. |
| A deploy action succeeds but the version is unchanged | Inspect pending state and robot-reported phases; a queued request is not completed activation. |
Continue with Servos, Marketplace and the remote-operation guide.